VoltQ Physical AI
infrastructure
Email us

Egocentric & SLAM training data for embodied AI, Physical AI & robotics teams Real factory floors. Real retail stores. Real car fleets.

Camera and sensor infrastructure is already live across our partner network.

Or write to raghav@voltq.com

VoltQ turns live camera and sensor infrastructure across 4,000+ real-world sites, run through our CCTV video analytics and wireless sensor partners, into structured training data for embodied AI, Physical AI and robotics teams building for the physical world.

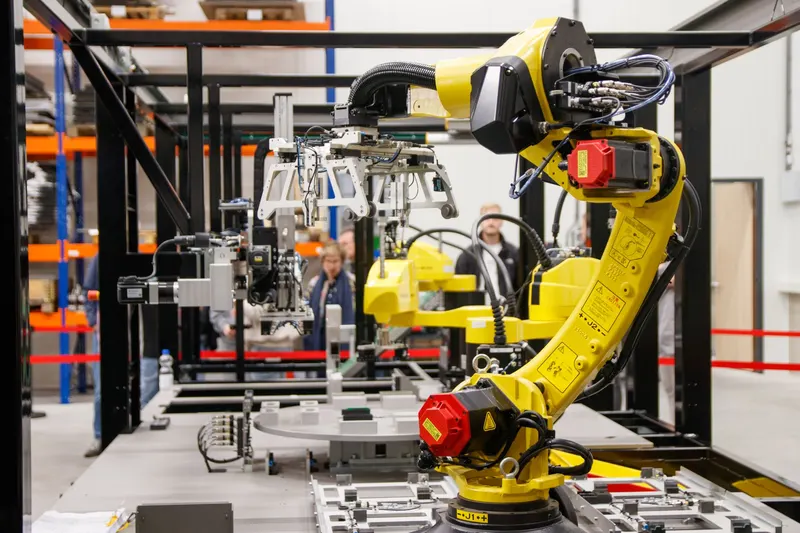
Illustrative photo: yellow industrial robotic arm in a factory test cell
Illustrative: industrial manipulation, the kind of work Physical AI teams are training robots to do.
4,000+
retail stores running camera analytics through our partners
500
stores with wireless people-counting sensors
100+
car fleets, with 1,000+ cars
120+
cities covered by our CCTV analytics partner

Data from the real world, for machines that operate in it

VoltQ builds access to real-world environments, people, factories and retail spaces to help Physical AI and robotics companies develop the next generation of intelligent machines.

From egocentric video, SLAM data and human activity to spatial, multimodal and industrial data, VoltQ helps robotics teams source the data required to train, evaluate and improve embodied AI systems.

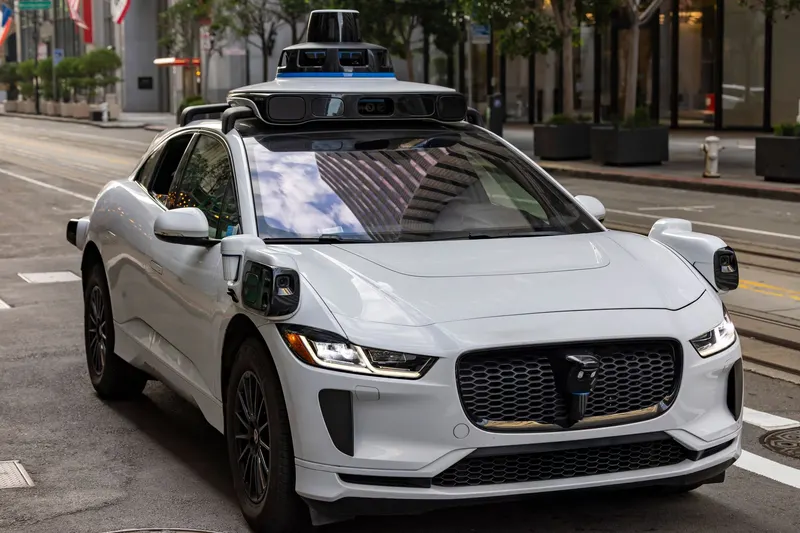
Illustrative photo: sensor-equipped car with a roof-mounted sensor pod on a city street
VoltQ's footprint includes 100+ car fleets with 1,000+ cars. (Illustrative photo, not a VoltQ vehicle.)

Third-person video shows the scene. It misses the task.

Robots trained on third-person footage learn to recognize actions from the outside. They miss the hand closing around a tool, the exact contact point, where the eyes moved half a second before the grip: the signals that separate a model that recognizes a task from one that can perform it.

That is why egocentric data, captured from the first-person view of someone actually doing the work, has become a default input for training Physical AI. And why spatial data from real, dynamic, GPS-denied environments is just as scarce for the navigation side of the same problem.

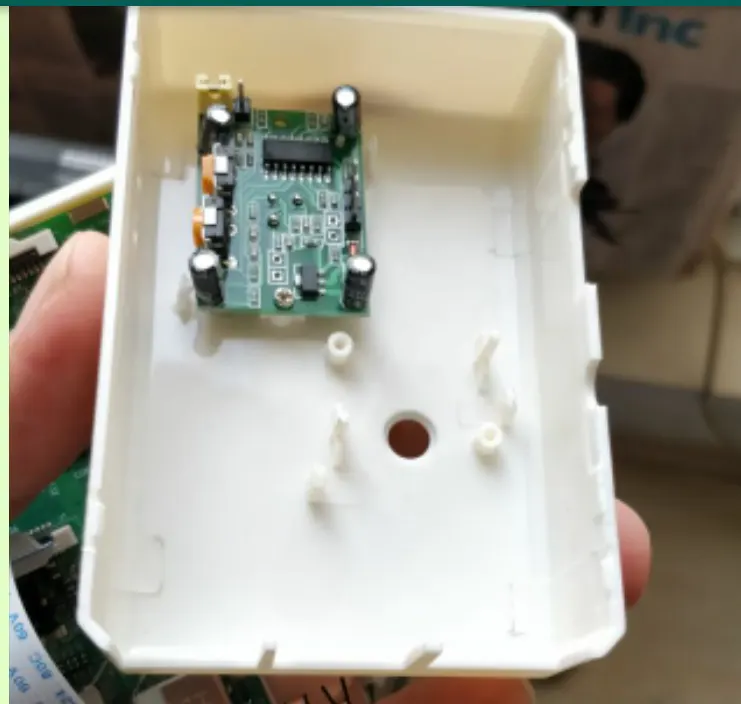
Raspberry Pi camera module used for counting store footfall, from VoltQ's retail deployments
A fixed footfall camera from our own retail deployments. It sees the scene from outside, not the hands doing the task.

Two data types, one physical footprint

First-person task video

Egocentric

First-person task video from real factory and retail workers: hand-object interaction, tool use, assembly, stocking, packing and customer-facing tasks. Captured where the work actually happens, not staged for a camera.

Egocentric use cases

Multi-sensor indoor data

Spatial / SLAM

Multi-sensor data from real indoor commercial environments: dynamic, cluttered, GPS-denied spaces that mirror exactly where mobile and service robots will need to operate. Camera and wireless-positioning data (Wi-Fi people counting) today, with IMU and depth capture on our roadmap.

SLAM use cases

The sensor infrastructure is already in place

Most egocentric and SLAM data providers start by building capture infrastructure from scratch: hardware, site access, a field workforce. We start from a different position. Through our CCTV video analytics and wireless sensor analytics partners, camera-based analytics already run across 4,000+ retail stores, wireless people-counting sensors are live in 500 of those stores, and an operations network is built for running physical rollouts at scale.

India's factory and retail floors are also some of the most varied working environments anywhere: different layouts, tasks, lighting and demographics than the home- and lab-collected datasets most Physical AI teams train on today.
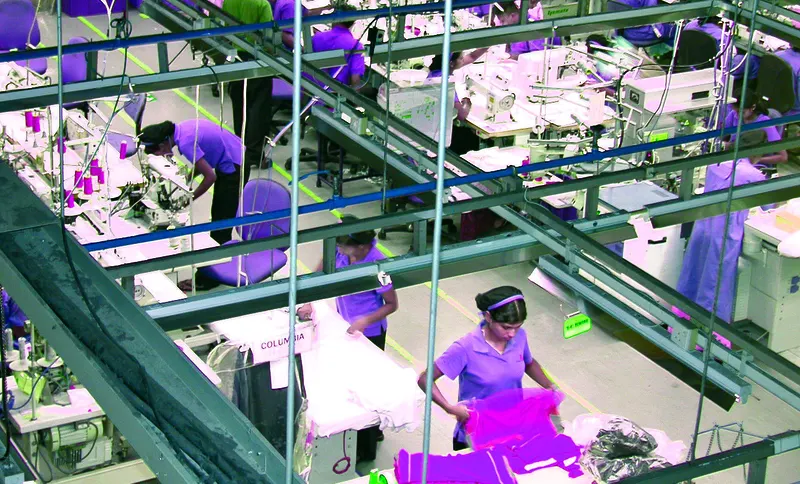
Garment factory floor in Noida with rows of sewing stations where RFID sensors are deployed
Garment factory floor, Noida, with RFID sensors deployed for lean manufacturing.

From scoping call to delivered dataset

You validate a small sample before we scale.

  1. Scoping call

    You tell us the task, environment and format you need.

  2. Pilot dataset

    We collect and deliver a small sample against your spec.

  3. Full collection

    Once validated, we scale collection across our site network.

  4. Delivery & support

    Structured delivery with documentation and an ongoing feedback loop.

Privacy and consent, first

Every site we collect from operates under a clear worker and customer consent process, with PII redaction built into the capture pipeline and full audit trails on request.

Data collection at this scale only works if it is done right. That is a floor for us, not a feature. Read our code of conduct.

  • Clear consent process for every worker and customer before capture
  • Faces and personal details removed or blurred before data leaves our pipeline
  • Every dataset ships with documentation of collection method, consent and redaction
  • Committed to complying with India's DPDP Act, the EU GDPR and local privacy regulations, and to the SOC 2 (AICPA) security criteria

Team associations

IIT, Rice University and KIT research background, with long service in publicly listed organizations.

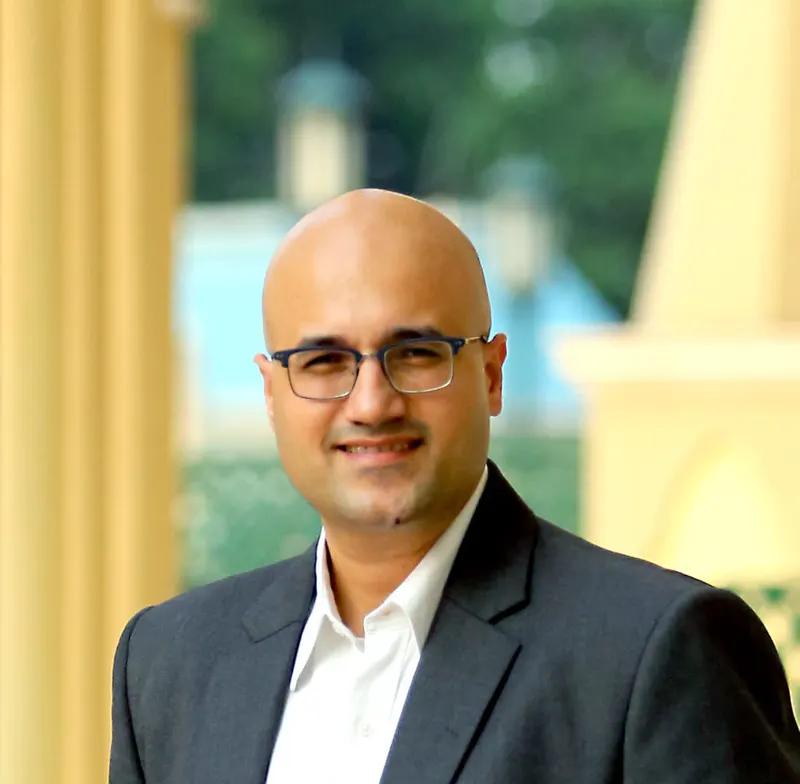
Portrait of Raghav Wahi

Raghav Wahi

Computer vision & sensor deployments

Has taken Raspberry Pi computer-vision and wireless sensors from prototype to production in retail stores and garment factories, including RFID for lean manufacturing. IIT BHU Varanasi (B.Tech) and Rice University (M.S.).

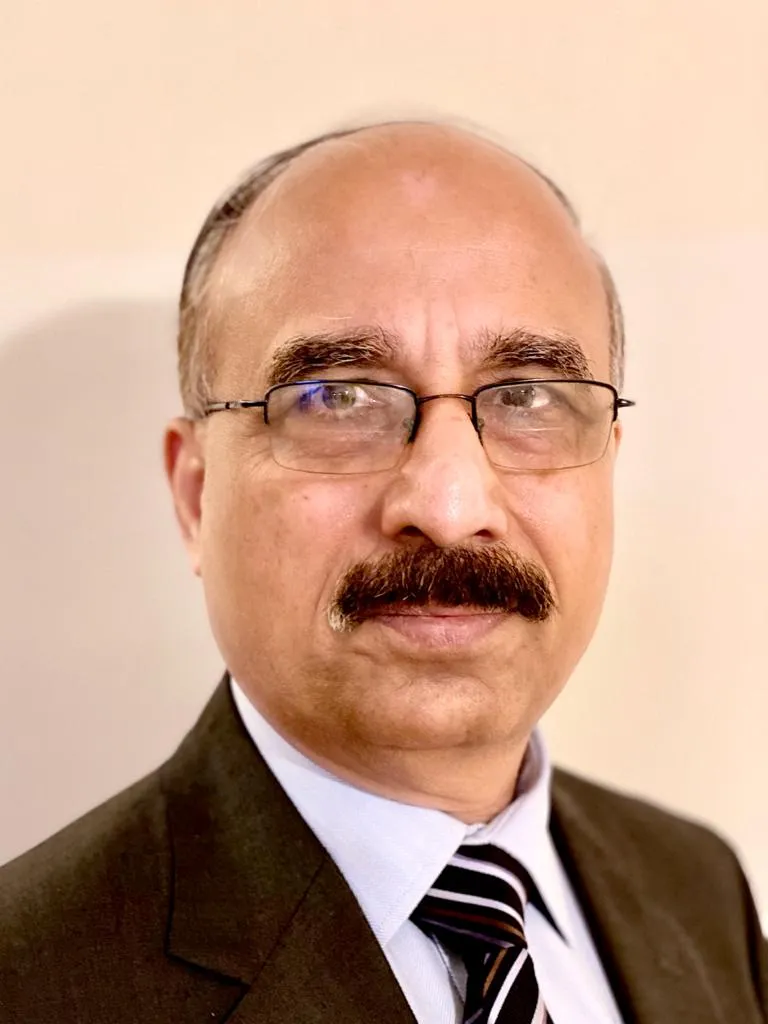
Portrait of Raghu Wahi

Raghu Wahi

Finance

Spent 39 years with ITC Ltd in the finance function and brings that financial discipline to VoltQ.

Academia & industry

  • Rice University
  • Karlsruhe Institute of Technology
  • Rensselaer Polytechnic Institute

Meet the full team

Logos show team members' education and employment history. They are not partnerships or endorsements.

Stop training on incomplete signals

Tell us the task, environment and format you need. We will come back with a pilot plan for a small sample dataset.